· robotics · kinematics · python
Sub-micrometer IK on a 4-DOF arm: analytical solutions + Newton-Raphson
For our Applied Robotics module at the University of Birmingham, a team of four of us built an autonomous fruit-sorting system on a Quanser QArm: a 4-DOF manipulator with an Intel RealSense D415 RGB-D camera, sorting 14 fruits into 3 baskets in both autonomous and teleoperated modes. My focus here is the part I find most interesting: the inverse kinematics.
Why analytical first
A 4-DOF arm admits closed-form IK. For a target pose, the geometry yields up to four candidate solution branches (elbow-up/down × shoulder configurations). Closed-form solutions are exact in theory and fast in practice — no iteration, no local minima. So we derived the analytical solution from the DH parameters and selected among branches with a joint-limit-aware rule: discard branches violating limits, then prefer the one closest to the current configuration to avoid large reconfigurations mid-task.
Why Newton-Raphson anyway
Real solvers accumulate floating-point error, and the analytical derivation assumes ideal geometry. We added a Newton-Raphson refinement stage on top of the closed-form seed: iterate on the pose error with the manipulator Jacobian until convergence. Because the seed is already near-exact, refinement converges in very few iterations.
The result: maximum round-trip error of 0.0002 mm — solve IK for a pose, run forward kinematics on the joint solution, measure the difference. For a fruit-sorting task this is overkill by orders of magnitude, which is exactly what you want from the layer you never want to debug again.
The rest of the pipeline
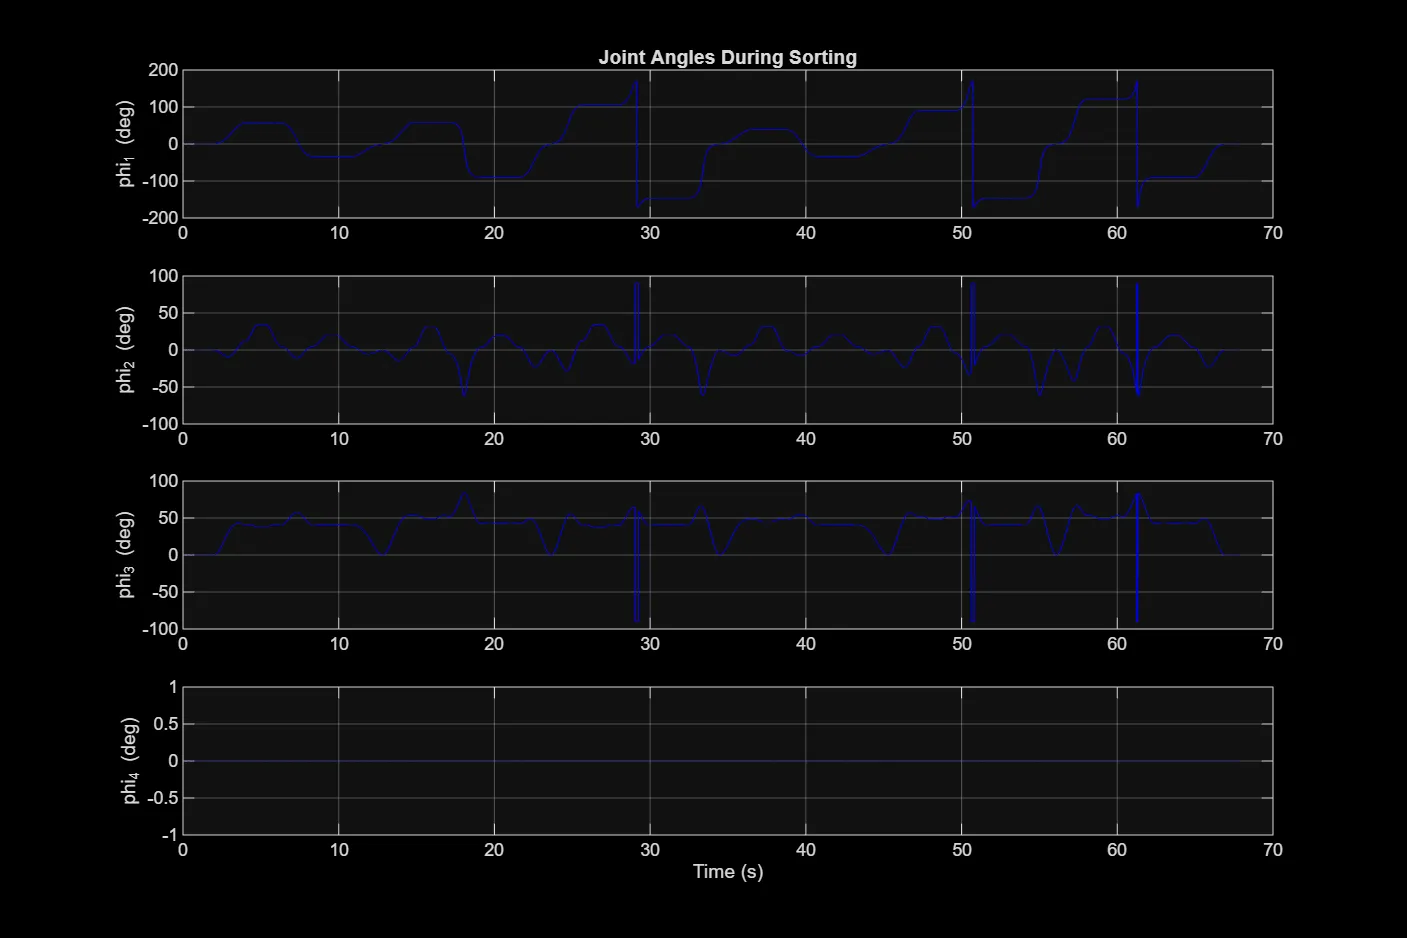
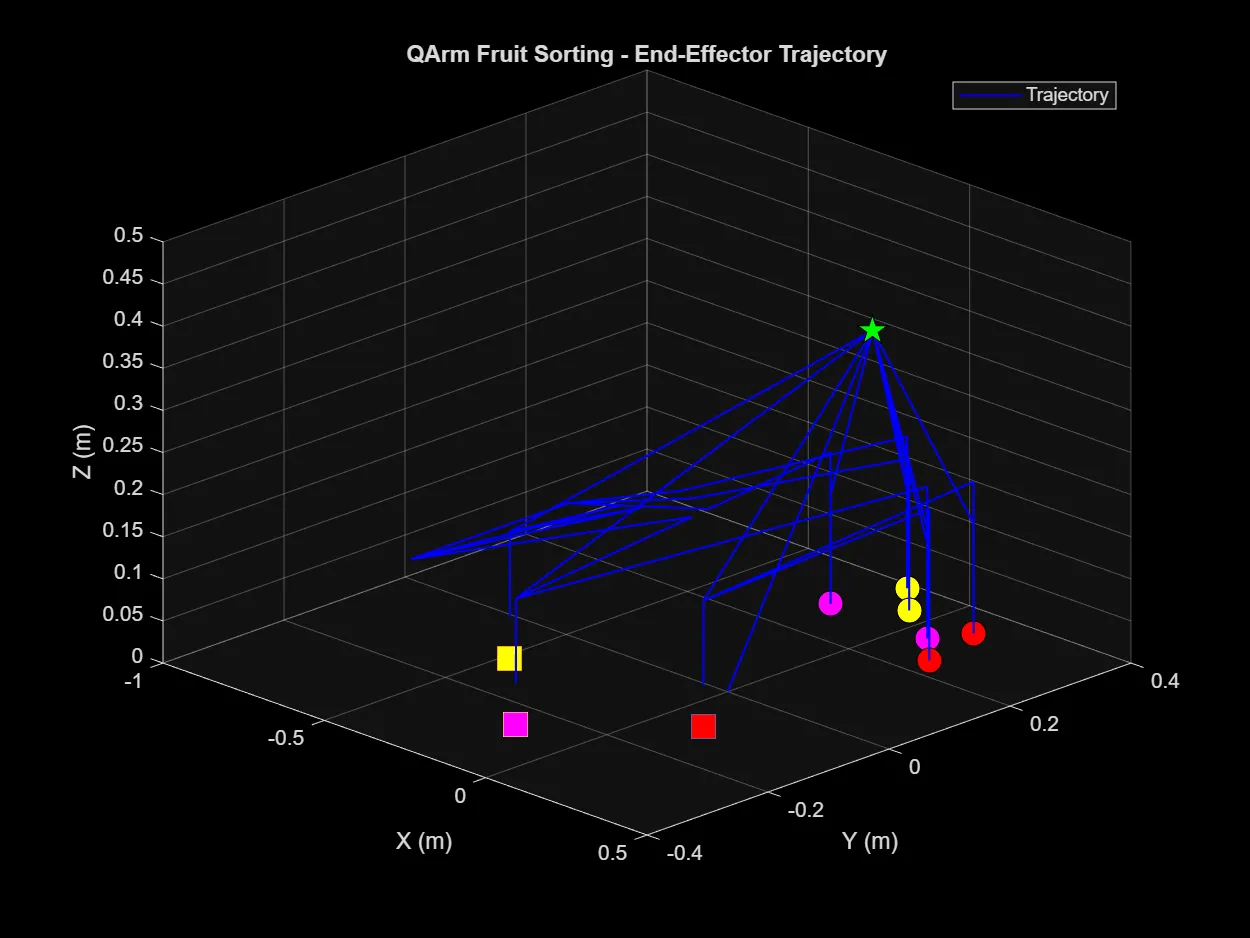
The IK sits inside a 13-state finite-state machine (INIT → SCAN → APPROACH → PICK → BASKET → PLACE, plus recovery states) with cubic rest-to-rest spline trajectories and Z-height safeguards against table collisions. Perception is HSV color plus circularity shape classification in OpenCV, back-projected to 3D with the D415 depth stream (1280×720 @ 30 fps). Hand-eye calibration uses the closed-form Umeyama SVD method, and a MATLAB/Simulink facade wraps the Python algorithms for an auditable control layer on the Quanser HIL stack.